Sang Min KimI am a Ph.D. student in Electrical and Computer Engineering at Seoul National University, advised by Prof. Young Min Kim, and I am currently a visiting student at the MIT Biomimetic Robotics Lab, hosted by Prof. Sangbae Kim. My research goal is generalizable manipulation. I believe each stage—from perception to control—offers problems that are easier to solve on its own terms, and generalization comes from weaving these solutions together across the full pipeline. Rather than specializing in a single stage, I want to be a generalist who spans the whole pipeline to build robots that manipulate reliably across novel objects, tasks, and environments. Email / CV / Google Scholar / Github / LinkedIn |

|
News
|
Research |
|
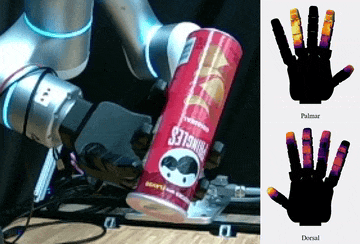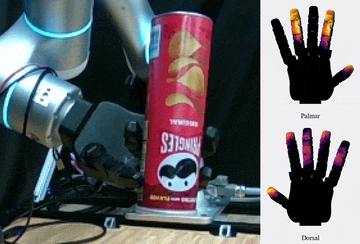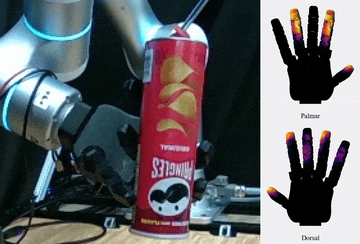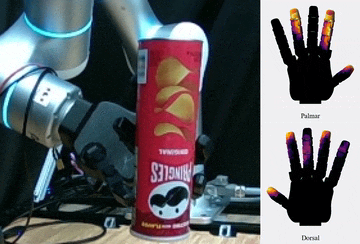
Real-Time Force Regulation for Whole-Hand Dexterous GraspingSang Min Kim, Alexander Alexiev, Tzu-Yuan Lin, Sangbae Kim, Young Min Kim*, Yonghyeon Lee* (*Co-corresponding authors) Preprint, 2026 project page / paper |
POIL: Point-based One-Shot Imitation Learning with Stable Dynamical SystemsSang Min Kim, Jinwoo Seo, Hyeongjun Heo, Junho Lee, Yonghyeon Lee*, Young Min Kim* (*Co-corresponding authors) Preprint, 2026 project page / paper |
|
|
See to Reach, Feel to Grasp: Learning a Blind Grasp Reflex for Anthropomorphic Robotic HandsAlexander Alexiev, Tzu-Yuan Lin, Sang Min Kim, Ho Jae Lee, Yonghyeon Lee*, Sangbae Kim* (*Co-corresponding authors) Preprint, 2026 project page / paper / video |

|
INGRID: Interactive Geometry and Instance Identification for Occluded ScenesJunho Lee, Sang Min Kim, Yonghyeon Lee, Young Min Kim Robotics: Science and Systems (RSS) @ SemRob Workshop, 2026 project page / paper |

|
AnyCamVLA: Zero-Shot Camera Adaptation for Viewpoint Robust Vision-Language-Action ModelsHyeongjun Heo, Seungyeon Woo, Sang Min Kim, Junho Kim, Junho Lee, Yonghyeon Lee, Young Min Kim IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 project page / paper |

|
Point2Act: Efficient 3D Distillation of Multimodal LLMs for Zero-Shot Context-Aware GraspingSang Min Kim, Hyeongjun Heo, Junho Kim, Yonghyeon Lee, Young Min Kim ICRA, 2026 project page / paper / code |

|
EUGens: Efficient, Unified and General Dense LayersSang Min Kim*, Byeongchan Kim*, Arijit Sehanobish*, Somnath Basu Roy Chowdhury*, Rahul Kidambi*, Dongseok Shim, Avinava Dubey*, Snigdha Chaturvedi, Min-hwan Oh, Krzysztof Choromanski* (*Equal contribution) NeurIPS, 2025 paper / code |

|
I2-SLAM: Inverting Imaging Process for Robust Photorealistic Dense SLAMGwangtak Bae*, Changwoon Choi*, Hyeongjun Heo, Sang Min Kim, Young Min Kim (*Equal contribution) ECCV, 2024 project page / paper |

|
NFL: Normal Field Learning for 6-DoF Grasping of Transparent ObjectsJunho Lee, Sang Min Kim, Yonghyeon Lee, Young Min Kim RA-L, 2023 project page / paper / video |

|
Robust Novel View Synthesis with Color Transform ModuleSang Min Kim, Changwoon Choi, Hyeongjun Heo, Young Min Kim Computer Graphics Forum (Proceedings of Pacific Graphics), 2023 project page / paper / code |

|
Balanced Spherical Grid for Egocentric View SynthesisChangwoon Choi, Sang Min Kim, Young Min Kim CVPR, 2023 project page / code / arXiv |
Misc |

|
Minicraft: ray-tracing version of minecraftGraphics Programming, SNU, Fall 2022 video Clone the minecraft with OpenGL. Implement the ray-tracing acceleration algorithm(3D DDA). |
| 🧩 |
Nonogram PuzzleMini game play A browser-based nonogram (picross) puzzle game with 15 puzzles ranging from Beginner to Expert difficulty. Fill in the grid guided by row and column clues to reveal the hidden picture. |
|
This template is a modification to Jon Barron's website. Find the source code to my version here. Feel free to clone it for your own use while attributing the original author Jon Barron. |