SNU ZERO
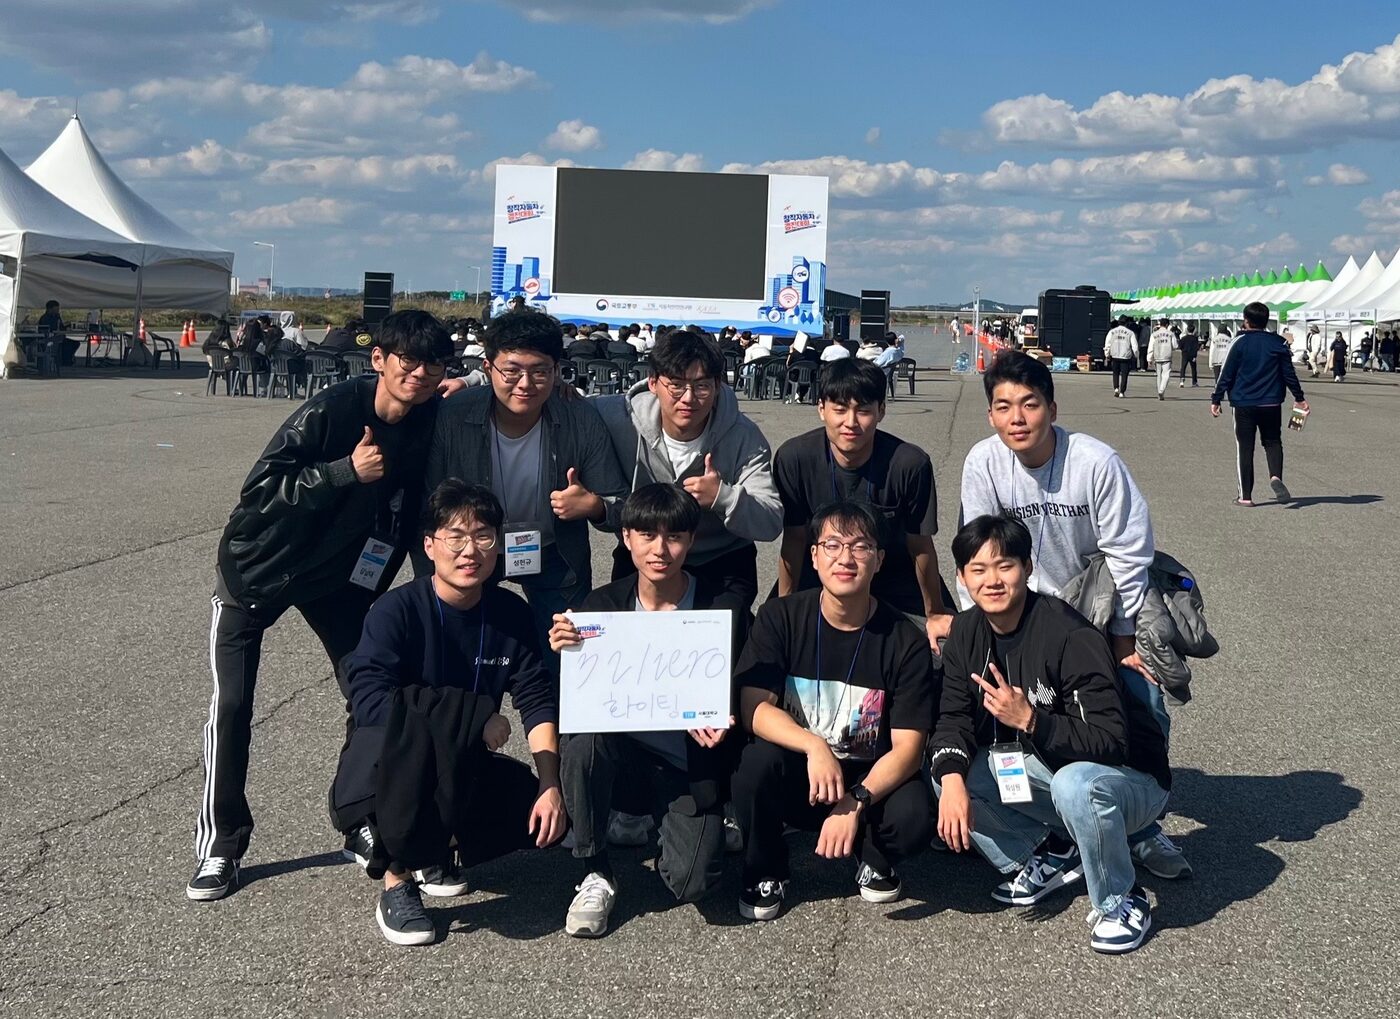
2022 International Student Car Competition (K-City)
With club members, we built a full ROS-based autonomous driving stack on the ERP42 platform (perception, localization, mission decision, path planning and control) and raced it in national student competitions. Below is my part of that work.
2022
- LiDAR point cloud preprocessing and costmap generation for the planner
- GPS-IMU fusion for vehicle localization
- LiDAR cone detection for the rubber-cone track
- Sensor driver setup and integration with the vision and planning modules
At K-City, a LiDAR connection failure ended our run. Building on this, the club added a system status monitor the following year, and the 2023 team placed 2nd.
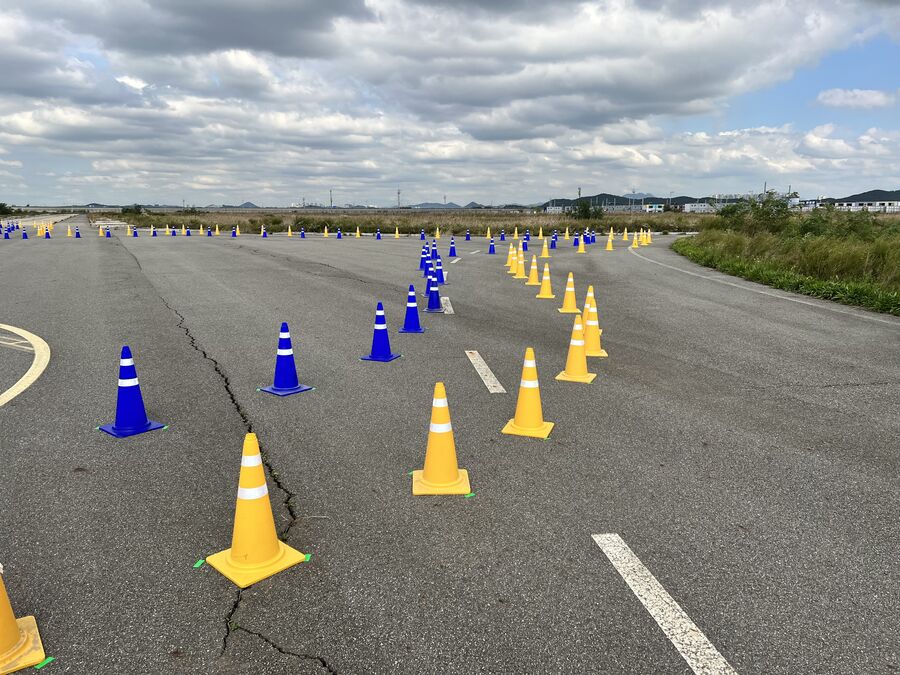
Rubber-cone track at K-City
2019
- Camera setup and homography for a bird's-eye view
- Lane, stop-line and crosswalk detection
- Local map generation from vision output
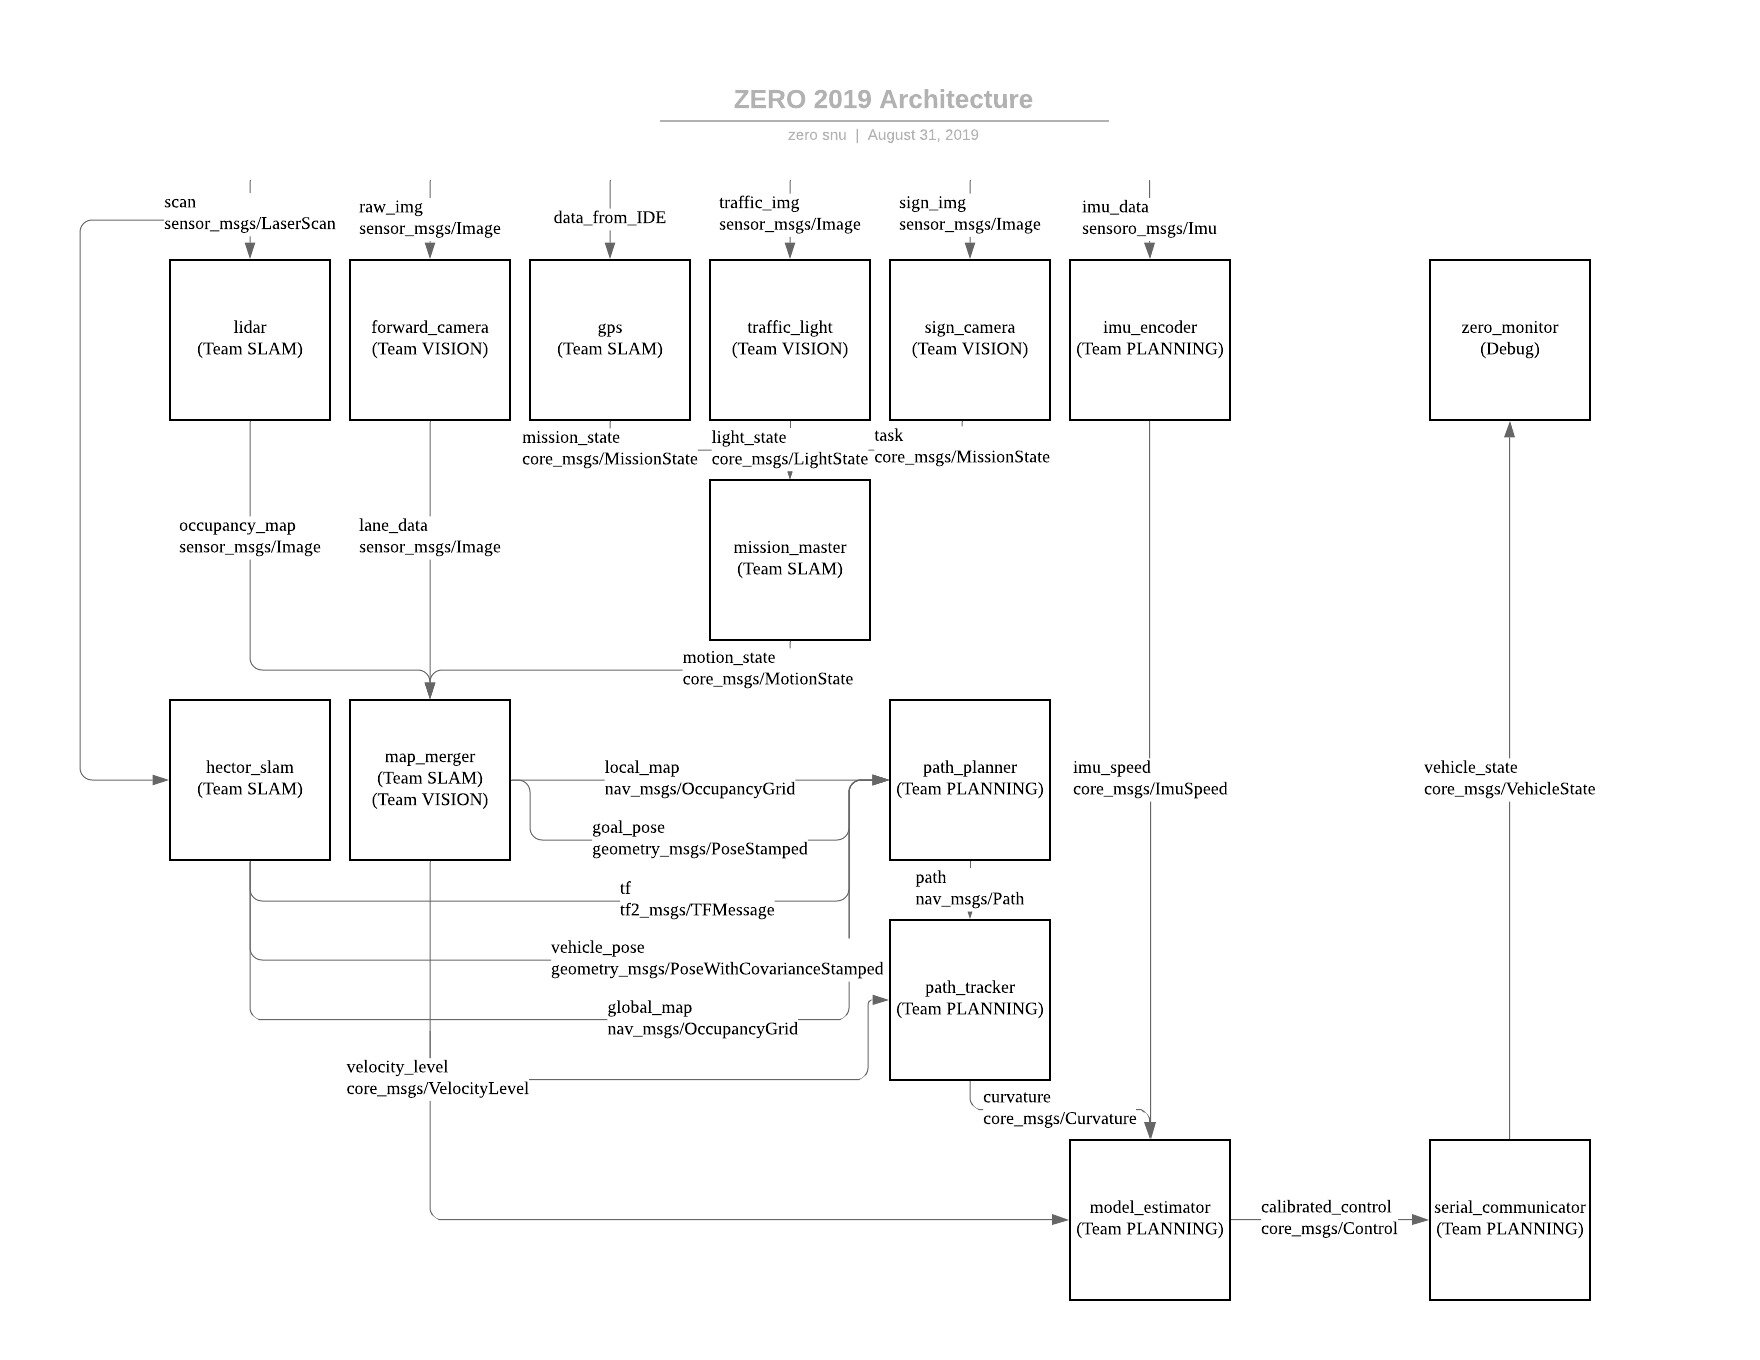
ZERO 2019 ROS node architecture (sensors → perception → mission master → planner → controller)
Teaching
Ran tutorials for new club members.
🤖
ROS TutorialROS basics for new members
Git & EditorGit, VSCode and Vim for new members (Nov 2019)